Stops before the drop
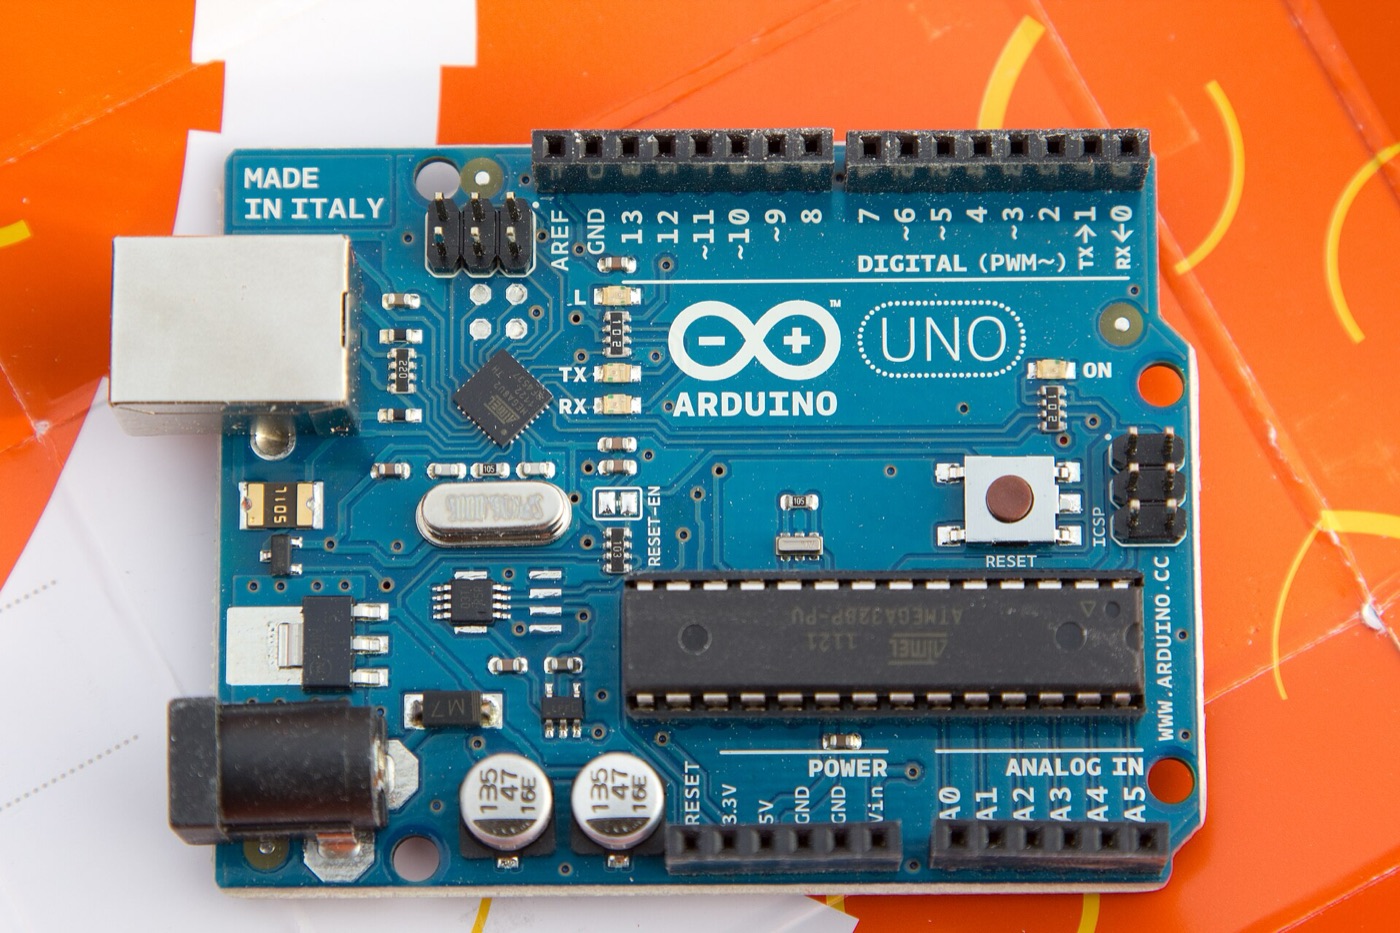
A smart wheelchair add-on: two HC-SR04 ultrasonic sensors and an Arduino UNO spot drop-offs and obstacles, then flash, beep and stop the motors. Select any part to magnify it.
- Floor sensor
- 12.0 cm
- Front sensor
- out of range
- Decision
- Ready
Loading the 3D model…
Eight parts, one job
Why edges matter
Most smart wheelchair projects look ahead. Falls happen at the floor’s edge.
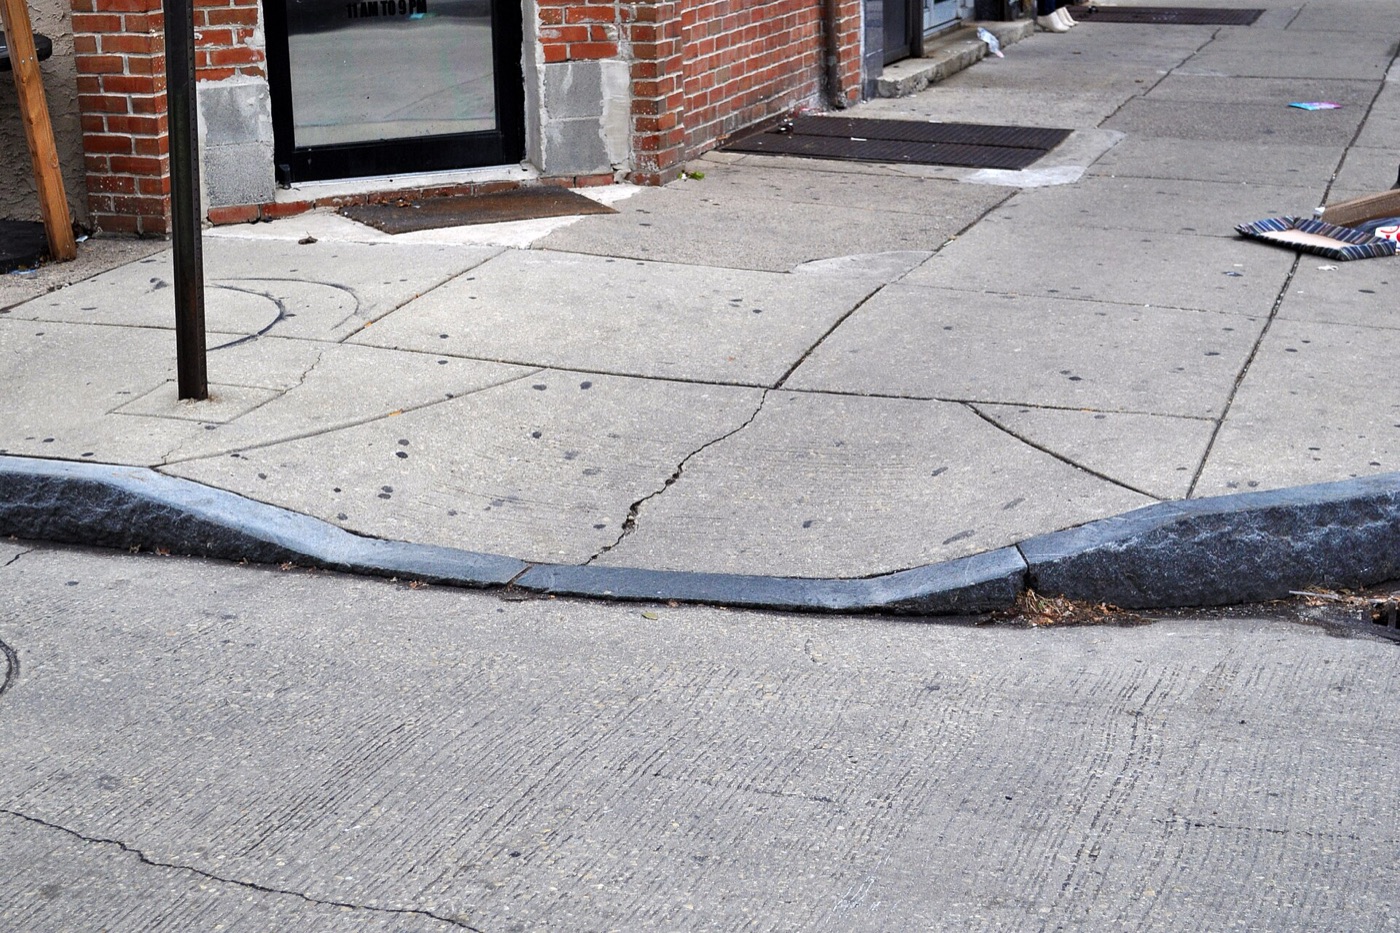
57.4%
of 577 manual wheelchair users had tipped over or fallen at least once. 15.8% of the injuries were serious.
Kirby et al., 1994
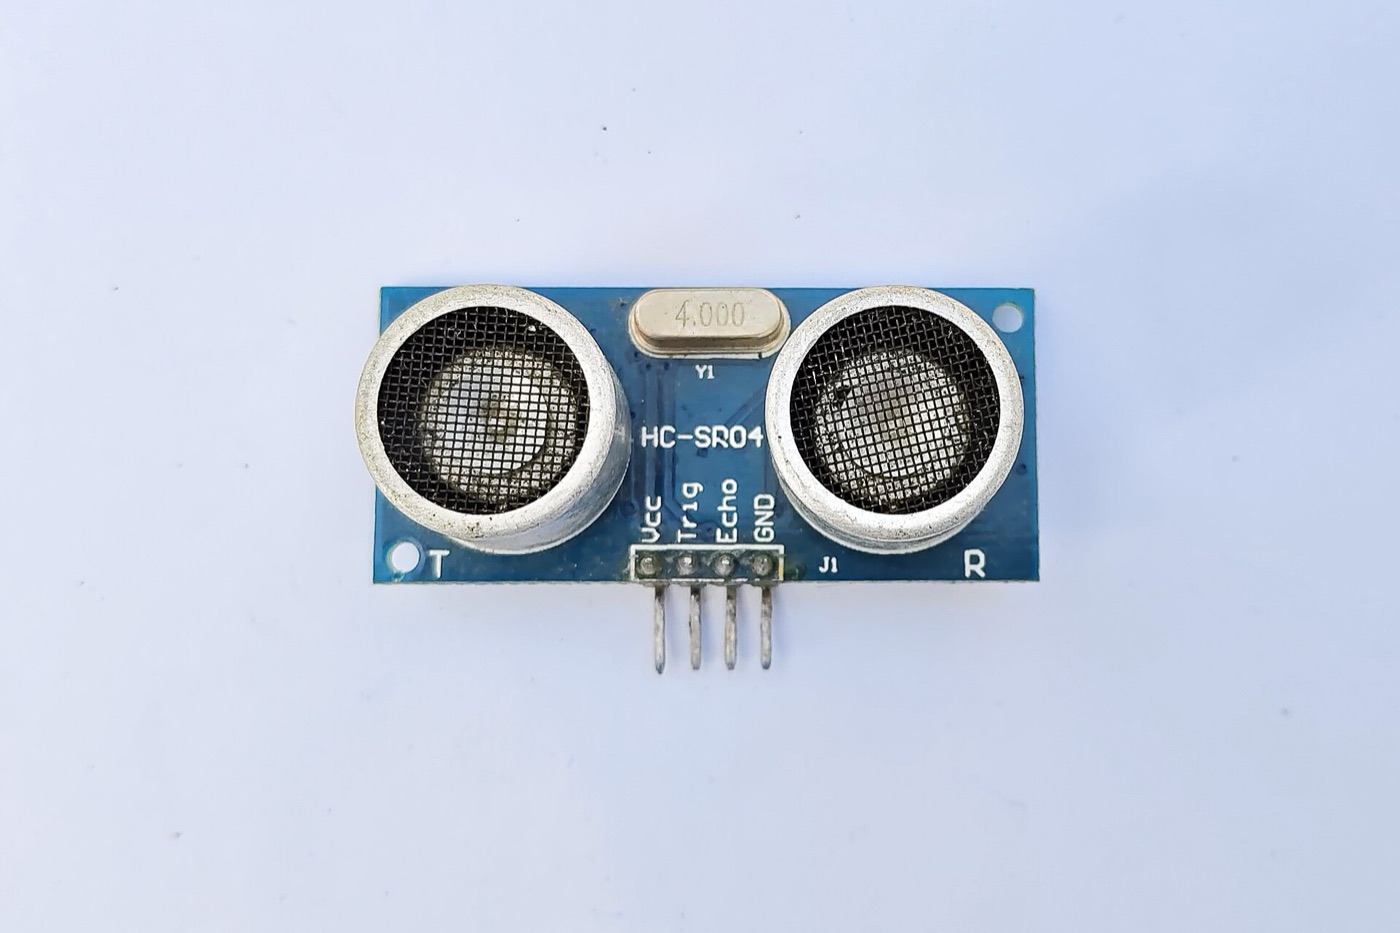
The sensor we use
- Measures 2 to 400 cm
- 15° listening cone
- 40 kHz sound pulses
- Starts on a 10 µs trigger
80 million
people, about 1% of the world, need a wheelchair to get around.
World Health Organization
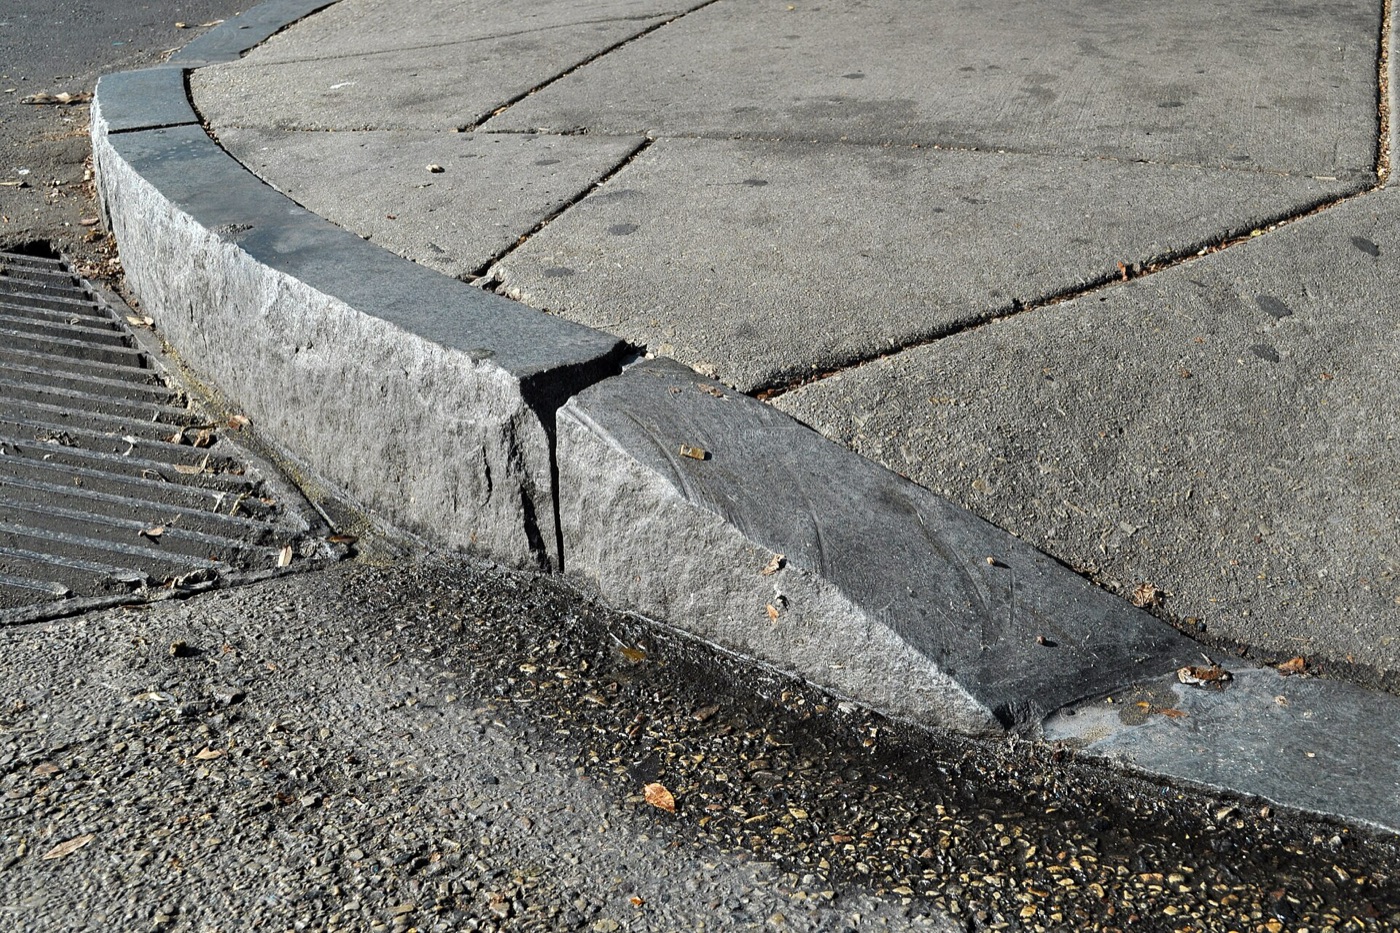
In crash tests, higher curbs were among the strongest predictors of a sideways tip.
Erickson et al., 2016
How it decides
About 30 times a second the Arduino pings both sensors, cleans the readings, and asks two questions. Has the floor dropped away? Is something too close? Run the demo above and the step it is on lights up here. Select any step to read what it does.